POSITION: TREASURER · IEEE RAS SBC (NITS)

DEBANGSHU
MOUNAS

Full Stack Software Engineer & Robotics Researcher. Architecting offline RL pipelines, autonomous aerial systems, and resilient production applications.

Focus SDE / ML / Gen AI
Degree B.Tech NIT Silchar
Status Open to Internships
ID: MOUNAS_D // NIT-S REC_ACTIVE
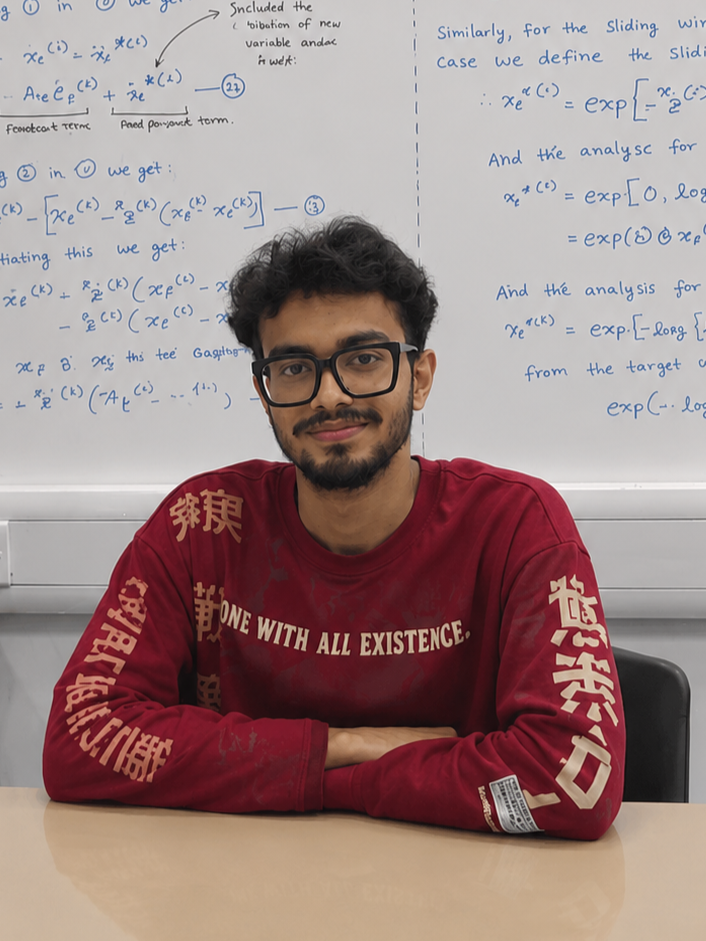
Debangshu Mounas
DEBANGSHU MOUNAS
RESEARCHER & BUILDER
+
/// ROBOTICS RESEARCHER /// OFFLINE RL /// AERIAL DRONE CROPPING /// FULL STACK & FLUTTER /// IEEE RAS TREASURER /// NIT SILCHAR /// SRIP IIT GANDHINAGAR /// SIH 2025 SELECTED /// CHEMATHON 2026 FINALIST /// ISRO IROC-U FINALIST /// NSCOT 2026 TOP 5 /// ROBOWAR 15KG WINNER /// /// ROBOTICS RESEARCHER /// OFFLINE RL /// AERIAL DRONE CROPPING /// FULL STACK & FLUTTER /// IEEE RAS TREASURER /// NIT SILCHAR /// SRIP IIT GANDHINAGAR /// SIH 2025 SELECTED /// CHEMATHON 2026 FINALIST /// ISRO IROC-U FINALIST /// NSCOT 2026 TOP 5 /// ROBOWAR 15KG WINNER ///
[01] Profile / Identity

Merging mechanical engineering with autonomous software intelligence.

I am Debangshu Mounas, Pre-Final year student at National Institute of Technology (NIT) Silchar. Currently serving as the Treasurer (former Academic & Research Secretary) at the IEEE Robotics & Automation Society (RAS) Student Branch Chapter.

My work spans offline reinforcement learning for tendon-driven robots, vision-based aerial multispectral imaging, full-stack microservices architecture, and combat robotics platforms. I build real systems where physical mechanics and intelligent software tightly converge.

Silchar, Assam, India Available for SDE / Robotics Roles
ML
RL
DL
Agentic AI
GEN AI
SDE
App Dev
Robotics
[02] System Specifications / Stack
01 // Languages
Python C++ C JavaScript TypeScript Dart SQL MATLAB Java
02 // AI & Agentic AI
Reinforcement Learning Offline RL (DQN/BC) PyTorch Computer Vision RAG & Embeddings LangChain ReAct Loops Function/Tool Calling LLM Evaluation
03 // Robotics & Autonomy
ROS / ROS2 Isaac ROS VSLAM Path Planning (RRT/A*) Sim-to-Real Deploy Sensor Fusion ArduPilot / UAV PID Control
04 // Full Stack & Mobile
Flutter React.js Next.js Node.js Express.js Django FastAPI REST APIs Riverpod Figma
05 // Databases & Infra
PostgreSQL pgvector MongoDB Firebase (RTDB/Firestore) Supabase Redis Celery Docker AWS (EC2) CI/CD & Git
06 // Embedded & CAD
NVIDIA Jetson STM32 ESP32 / Arduino Actuator & Drives SolidWorks Fusion 360 ANSYS (CFD / FEA) LoRaWAN
[03] Career Logs & Research Appointments

SRIP Research Intern – Robotics & AI Systems

MAY 2026 – JULY 2026 [COMPLETED]
@ Indian Institute of Technology (IIT) Gandhinagar · Advisor: Prof. Madhu Vadali
  • Implemented offline reinforcement-learning training and evaluation (behavior-regularized Double DQN with behavior cloning) for a tendon-driven soft robot using 21,102 transitions from 775 teleoperated trajectories.
  • Coupled Isaac ROS, RealSense D435i, VSLAM, and a 3D RRT global planner with a learned local policy on NVIDIA Jetson Xavier NX; constructed real-time telemetry GUI.
  • Evaluated hierarchical navigation over 90 physical trials across 30 unseen layouts, achieving a 91.1% success rate with zero online fine-tuning.

Software Engineer Intern

JAN 2026 – MAY 2026
@ Grepin · Gurgaon, Haryana
  • Engineered concurrent synchronization between Firebase Realtime Database and Firestore for multi-role dashboards using OOP patterns across asynchronous streams.
  • Refactored a 16,500+ line production codebase, eliminated memory leaks, and raised frontend benchmark responsiveness.

Software Engineer Intern

NOV 2025 – DEC 2025
@ Konect U · Mumbai, Maharashtra
  • Engineered REST API aggregation engine for parallel queries across three ride-hailing services with fallback redundancy; shipped in a consumer app with 50 Lakh+ downloads.
  • Configured PhonePe SDK payments, OAuth webview pipelines, and Firebase Cloud Messaging for push dispatching.
[04] Engineered Systems / Selected Works
LeaseLens AI SAAS / AGENTIC

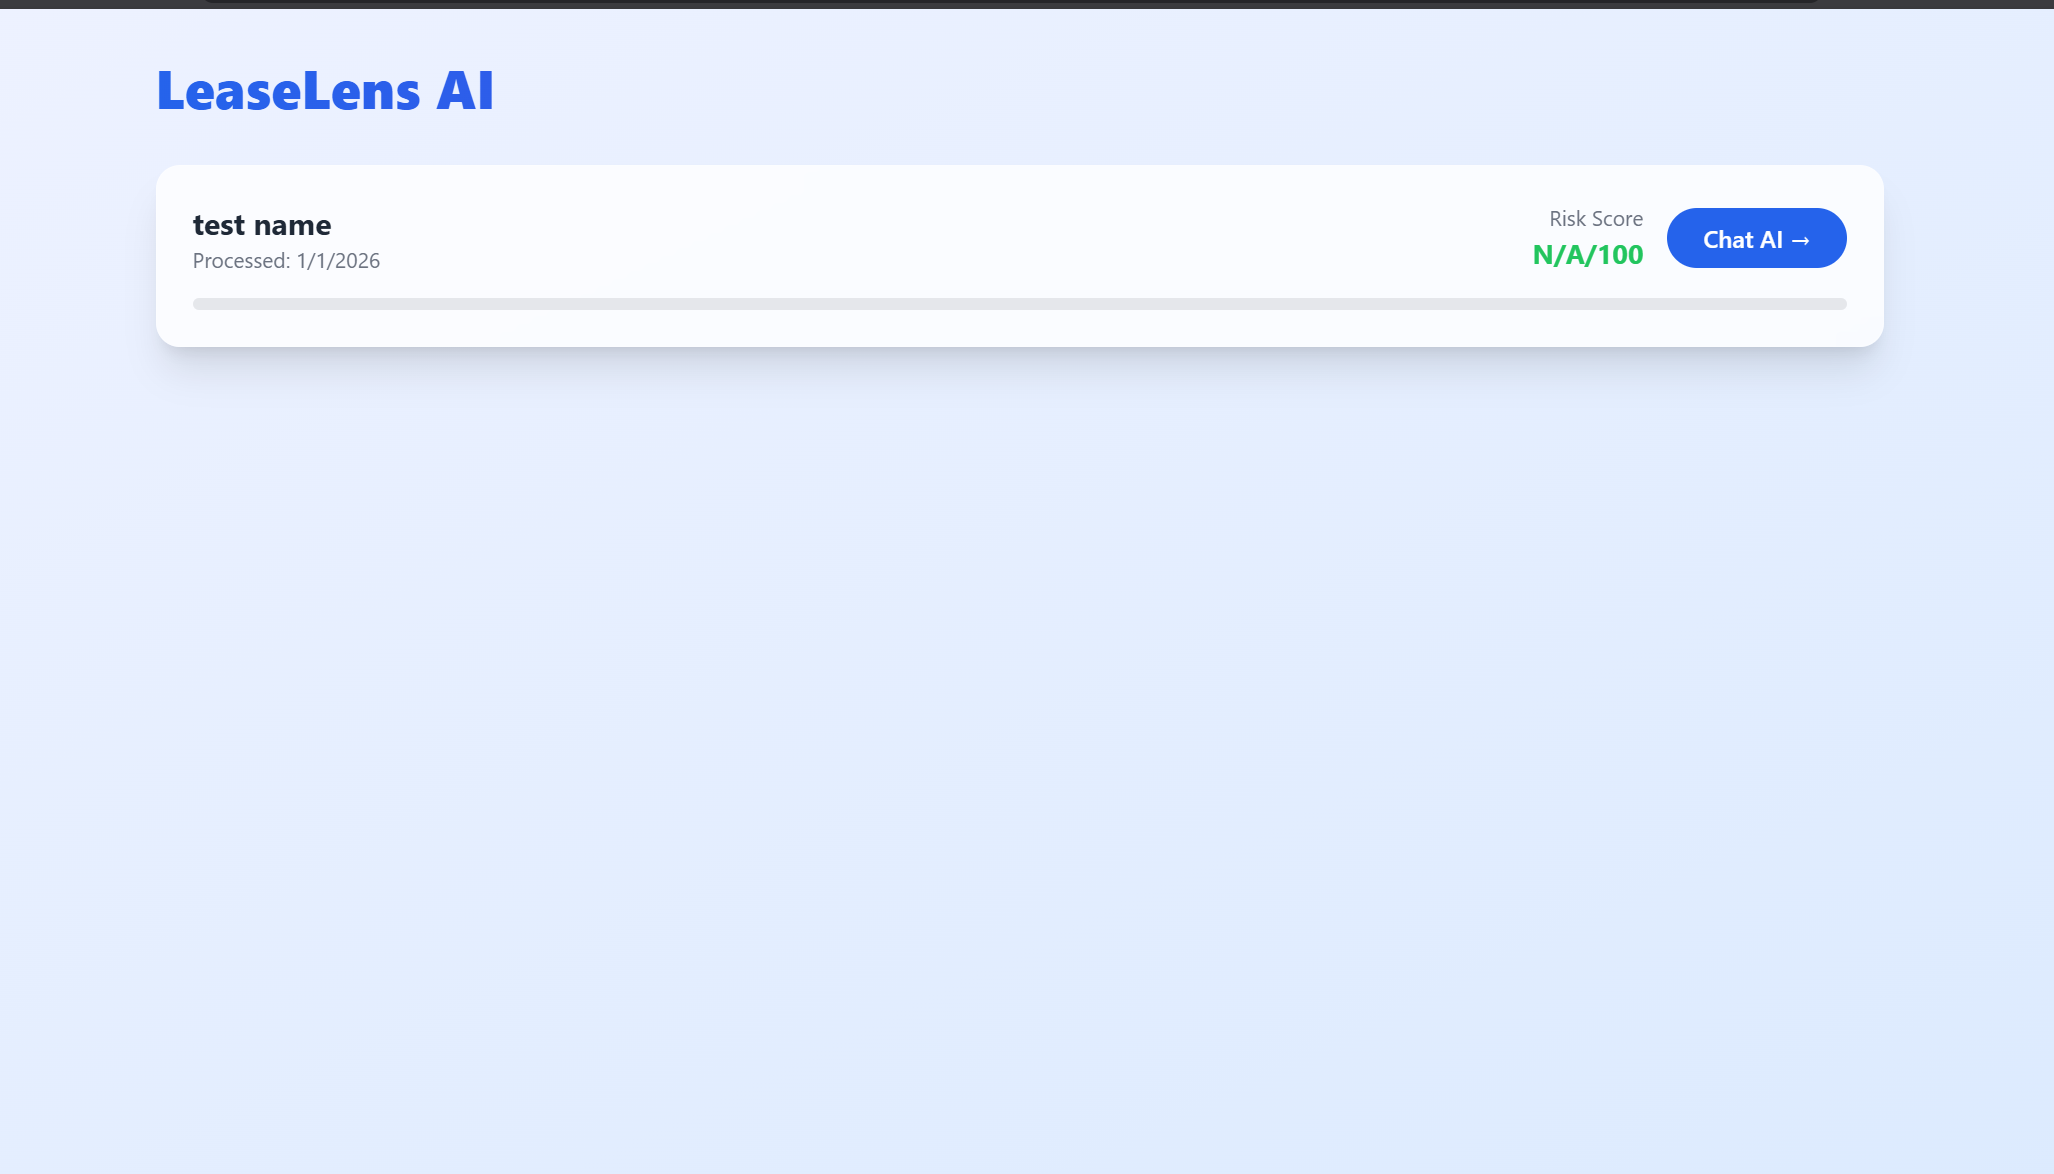
LeaseLens AI

Full-stack event-driven document intelligence platform using Celery, Docker, pgvector, and Gemini AI for automated lease clause audit and sub-second retrieval.

Django React pgvector Celery AWS
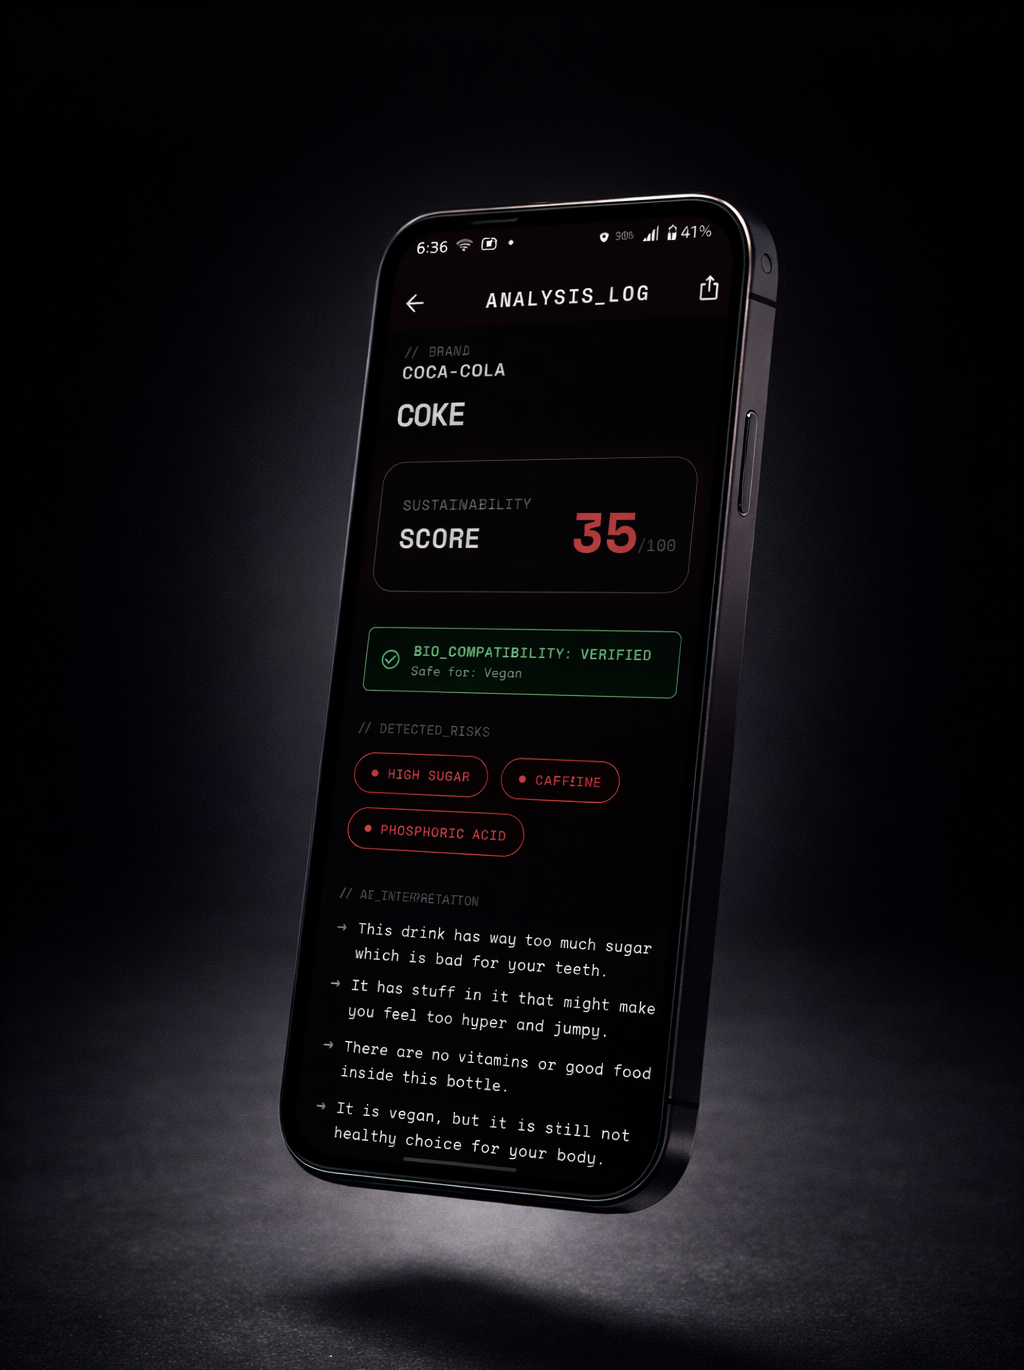
EcoSnap MOBILE / ML

EcoSnap

Real-time mobile audit terminal combining on-device computer vision (ML Kit) and Supabase backend to perform instant packaging sustainability classification.

Flutter Supabase ML Kit Riverpod
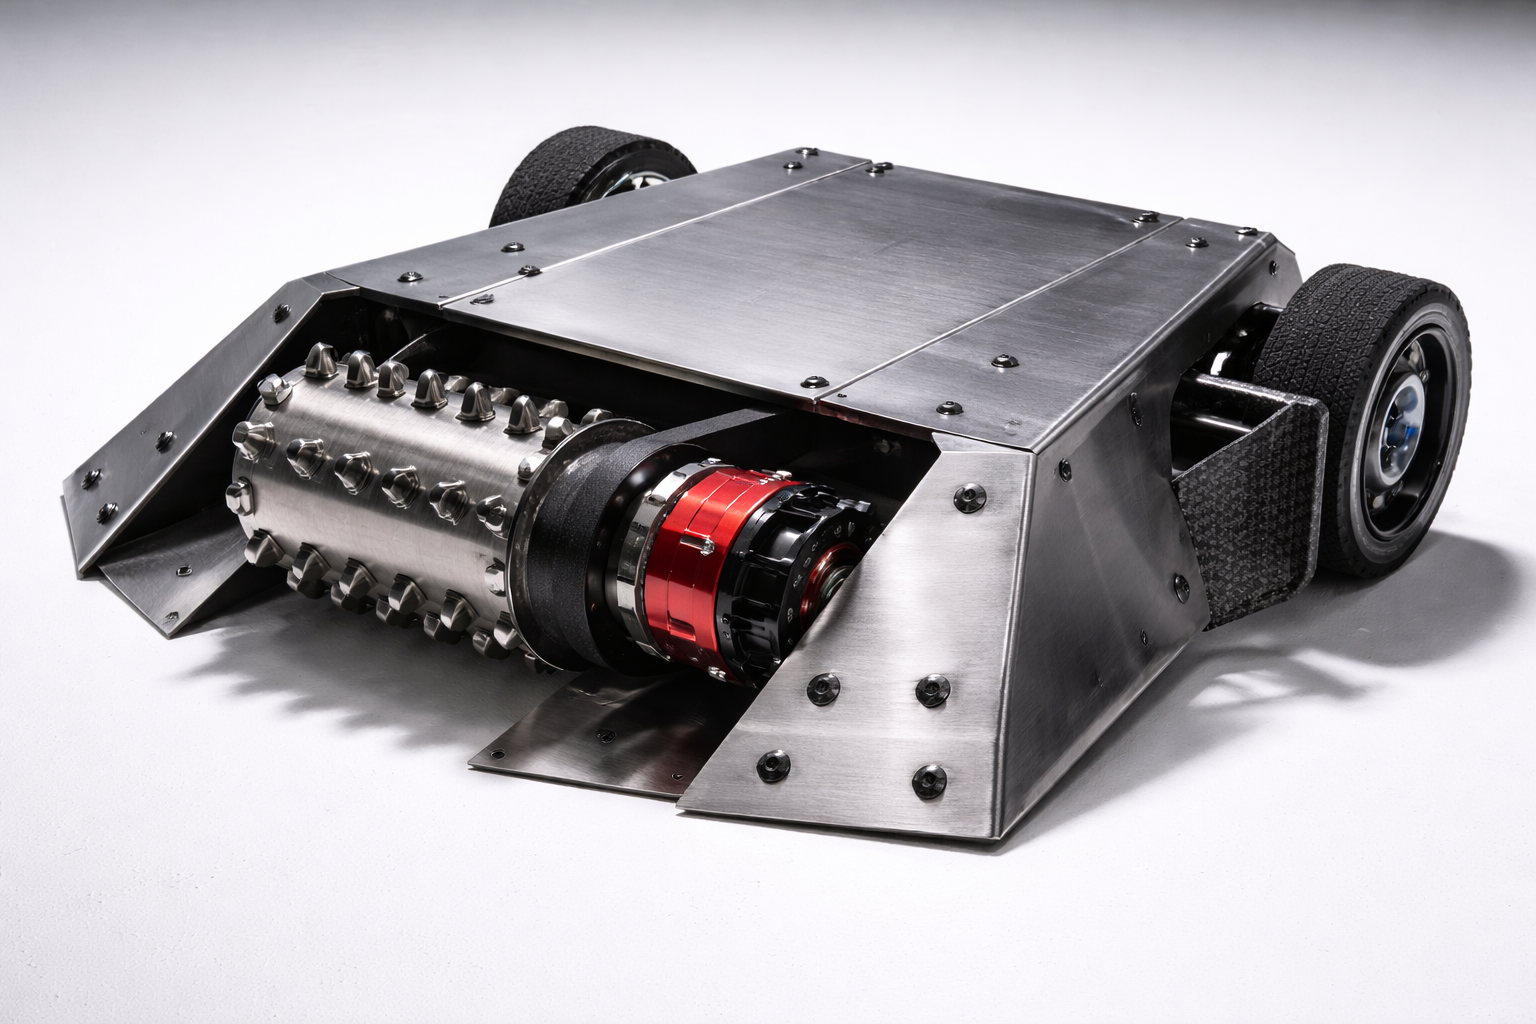
RoboWar Bot CHAMPION

RoboWar 15kg Combat Bot

Custom CNC aluminium combat chassis designed in SolidWorks with high-torque brushless drive train and reinforced impact armor. Winner at Tecnoesis 2026.

SolidWorks Robotics Kinematics RC Systems
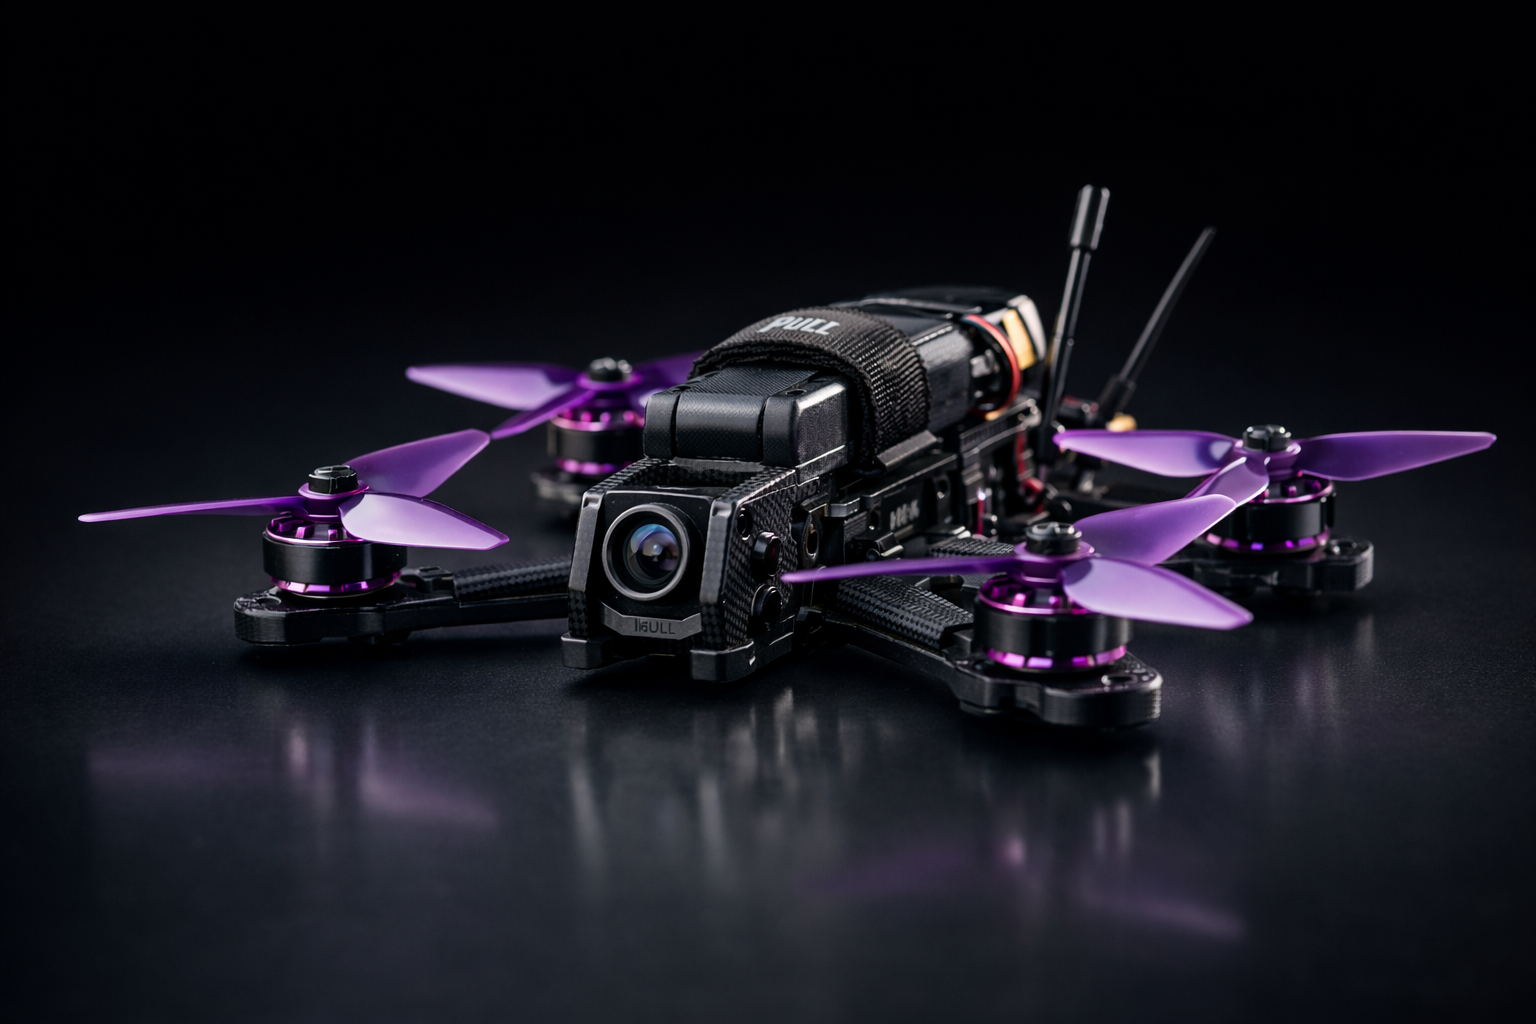
Autonomous UAV AERIAL ROBOTICS

Waypoint GPS Quadcopter

Custom autonomous aerial platform running on ArduPilot with onboard GPS-lock stabilization, ELRS low-latency control, and long-range telemetry downlink.

ArduPilot ELRS UAV Avionics Telemetry
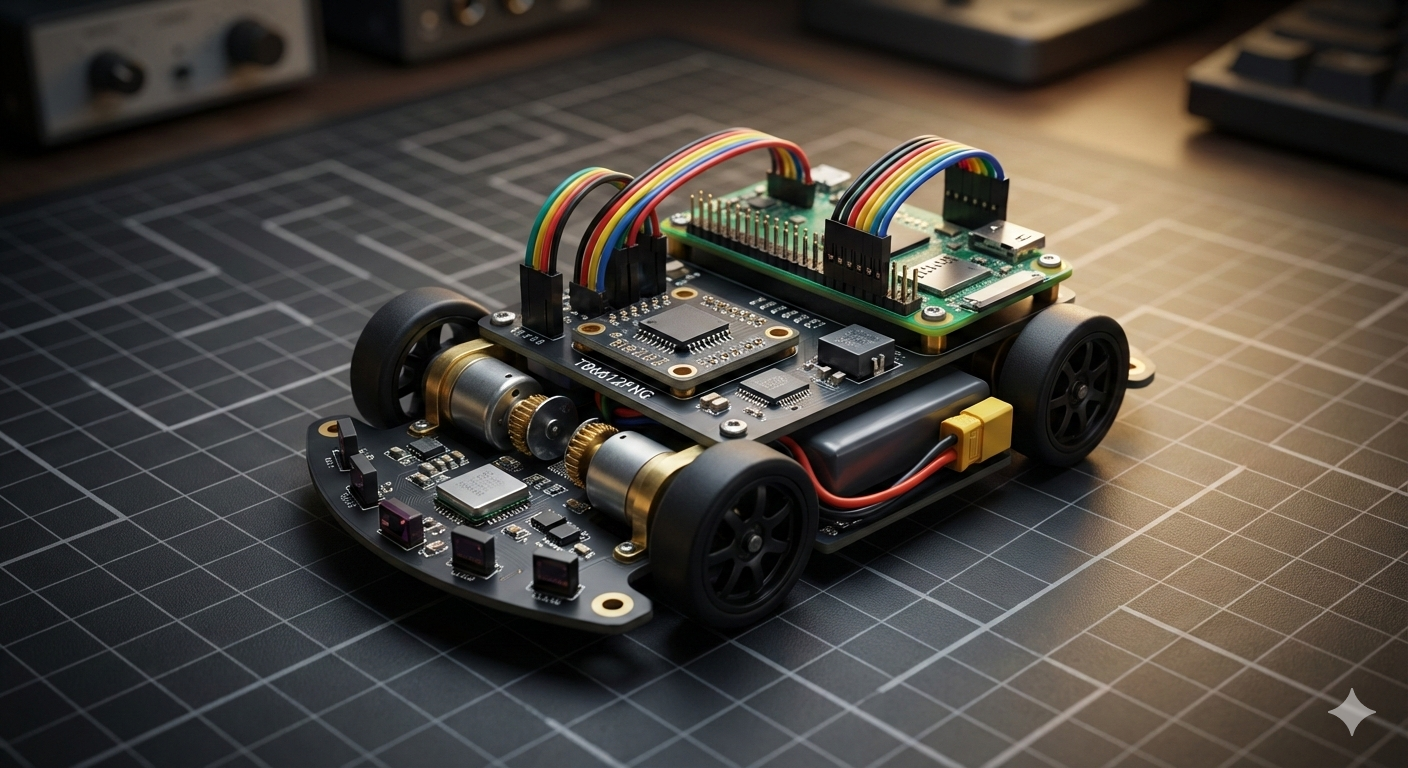
Micromouse EMBEDDED NAV

Micromouse Maze Solver

High-speed autonomous maze mapping vehicle equipped with ToF laser arrays, 6-DoF IMU orientation stabilization, and flood-fill shortest-path optimization.

STM32 PID Control FloodFill Sensor Fusion
Robotic Arm MECHATRONICS

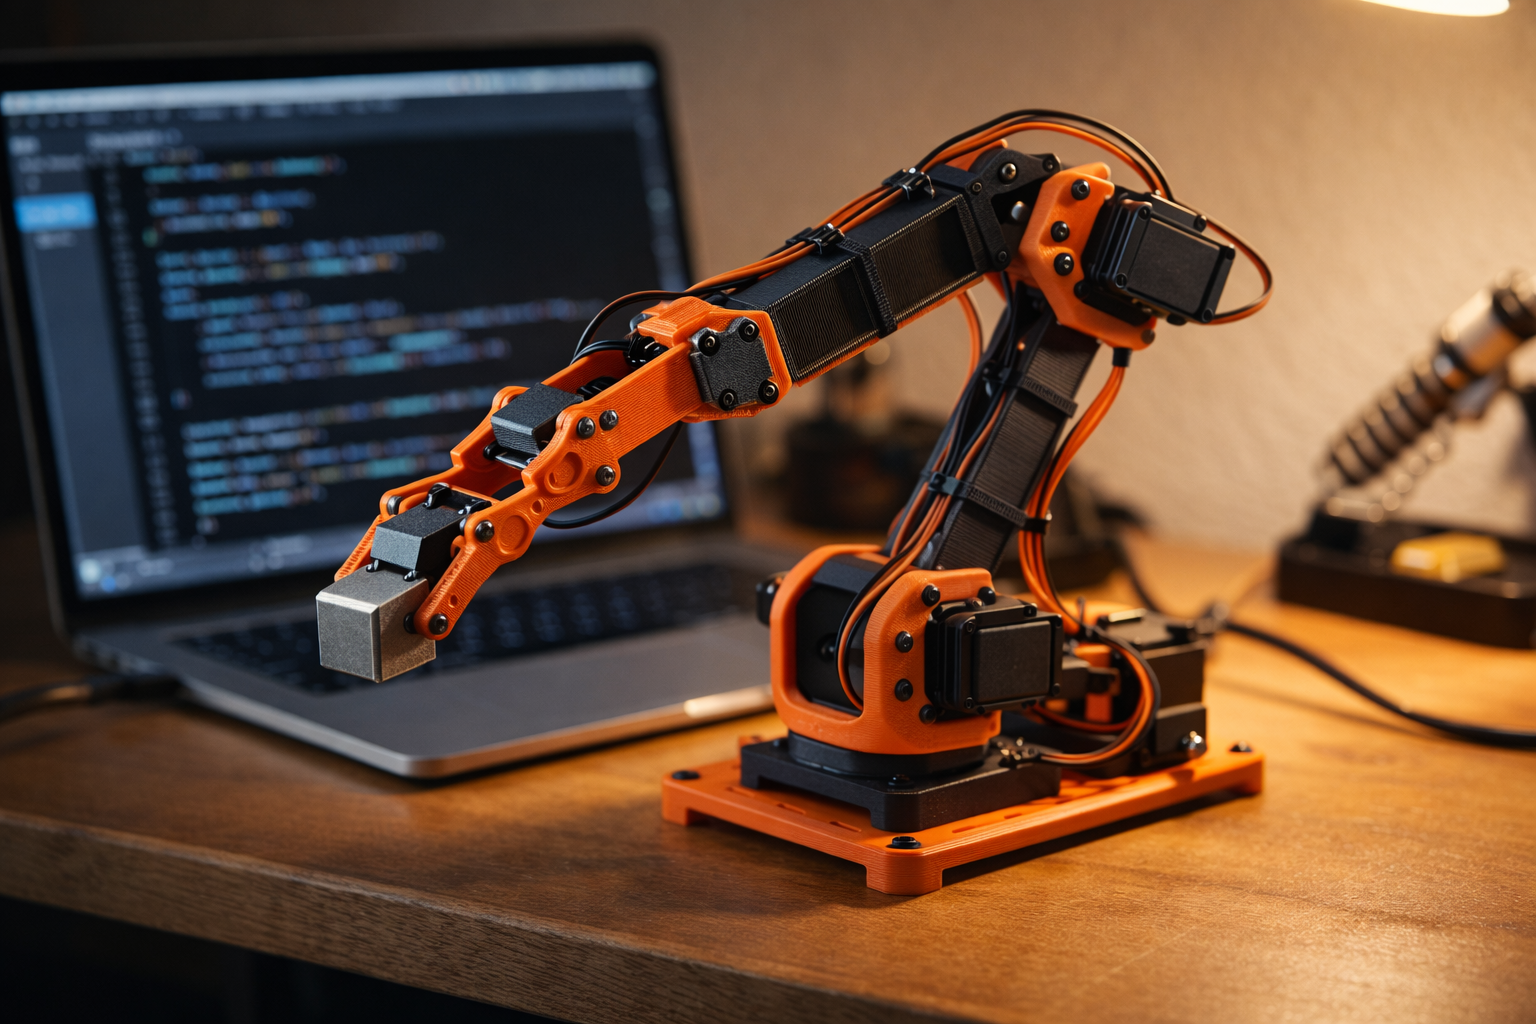
4-DOF Articulated Manipulator

Custom 3D-modeled robotic manipulator using high-torque metal gear servos, inverse kinematics positioning, and serial trajectory interpolation.

SolidWorks Kinematics Arduino Actuation
[05] Peer-Reviewed Papers & Preprints
SUBMISSION ICRA 2026 (IEEE Int. Conf. on Robotics & Automation)

A Closed-Loop Aerial Pipeline for Multispectral Crop Monitoring and Targeted Intervention

Engineered an end-to-end autonomous UAV framework synthesizing real-time multispectral vegetation index mapping (NDVI/NDRE) with onboard trajectory planning to enable localized micro-targeted agricultural intervention without ground station latency.

// Aerial Robotics // Multispectral Vision // Closed-Loop Control
UNDER REVIEW IEEE Transactions

Offline RL for a Tendon-Driven Soft-Legged Quadruped Robot (SLOT)

S. Karan, D. Mounas, M. Vadali

Hierarchical offline-RL navigation system (3D RRT planner + behavior-regularized Double DQN) trained on 21,102 real-robot transitions, deployed with zero online fine-tuning: 91.1% success rate across 90 physical trials in 30 unseen layouts.

// Reinforcement Learning // Soft Robotics // Sim-to-Real
PUBLISHED Springer LNCS · RIC 2025 Selected Presentation @ IIT Guwahati

Smart Flood Detection & Traffic Management: IoT/ML for Urban Resilience

D. Mounas, N. Islam, D. Goswami

Hybrid XGBoost/LSTM flood-forecasting pipeline (94% accuracy) linked to an automated A*-based dynamic traffic rerouting mechanism over LoRaWAN sensor networks.

// Urban Resilience // LoRaWAN // Predictive ML
[06] Competitions & Accolades
NATIONAL TOP 5 2026

NSCOT National Ocean Challenge

Team Lead for 3-Autonomous Surface Vessel system for magnetic anomaly detection (sub-metre target precision).

TOP 16 NATIONALLY 2025

ISRO Robotics Challenge (IRoC-U)

Software & Design Lead for ROS2 autonomous rover navigation and SolidWorks chassis design under space constraints.

CHAMPION 2026

RoboWar 15kg Winner

Tecnoesis 2026. Designed, engineered and piloted heavy combat chassis to 1st place victory.

INSTITUTE LEVEL 2025

Smart India Hackathon (SIH)

Selected at Institute Level (NIT Silchar) for national innovation challenge.

FINALIST 2026

IIChE ChEMATHON · IIT Patna

National Level Finalist solving computational industry process optimization.

3-STAR 1583 PEAK

CodeChef Competitive Coding

Active competitive algorithmic solver on arrays, dynamic programming, and graph theory.

[07] Live Activity Matrix
GITHUB // @DMounas LIVE_POLL
Public Repos --
Followers --
Commit Matrix // 2025–2026 Calendar LIVE_GRID
GitHub Contributions - Debangshu Mounas
Less Activity
More Activity
OPEN GITHUB PROFILE ↗
LEETCODE // @vLp1PBsG1o ALGORITHMS
LeetCode Heatmap
[08] Communication Uplink

Transmit a message.

Interested in discussing autonomous systems, offline RL, full-stack software development, or prospective internship opportunities? Leave a packet below or contact directly.

RESPONSE TIME: < 24 HOURS
TIMEZONE: IST (UTC +5:30)